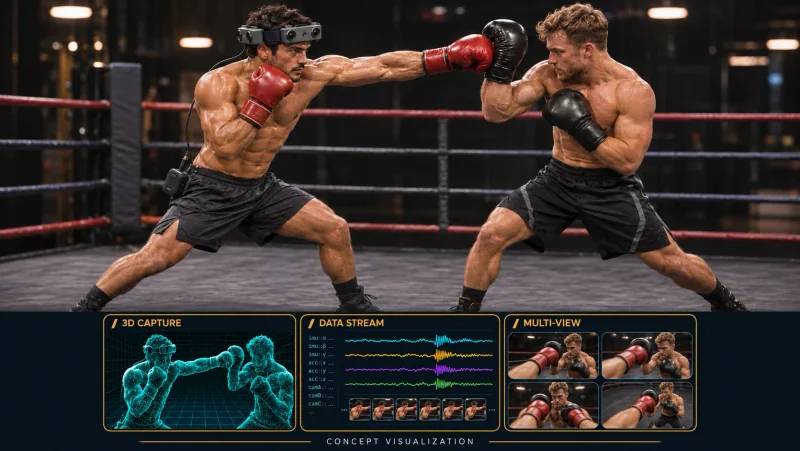
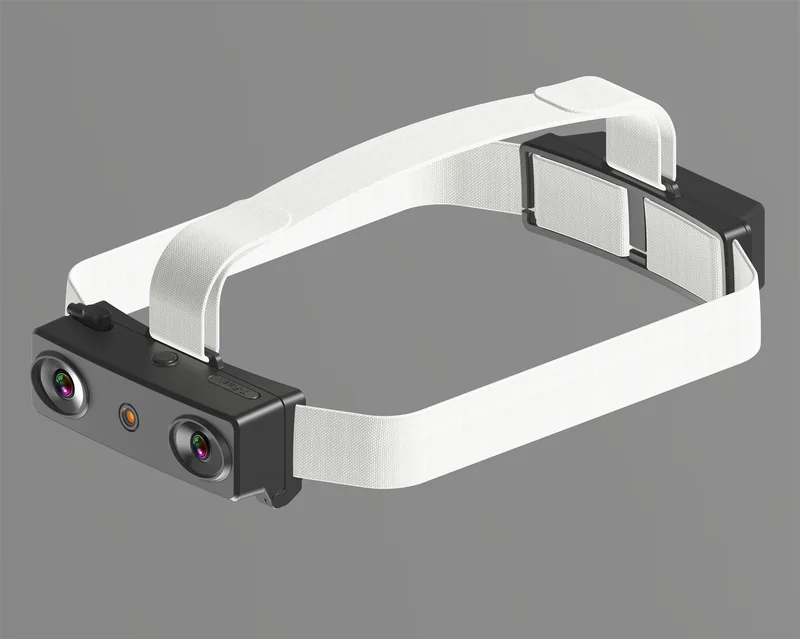
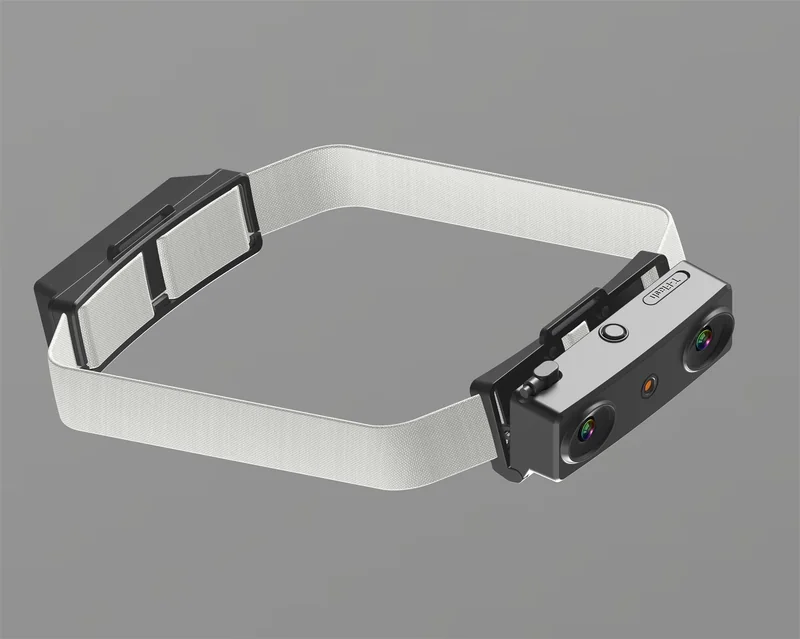
Plan 3D hand object interaction data collection with R10: record a sparring round in synchronized views and manually index glove contact, recovery and guard changes.
Source: BoxingVI: Action Intervals /Author: TINTELE GLOBAL CO., LIMITED Editorial Team
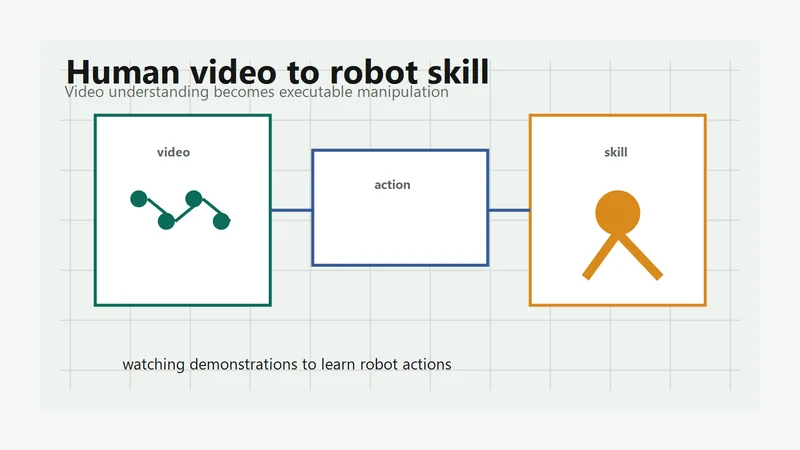
This Human-to-Robot pipeline separates video understanding from robot imitation, turning observed actions and objects into structured manipulation skills.
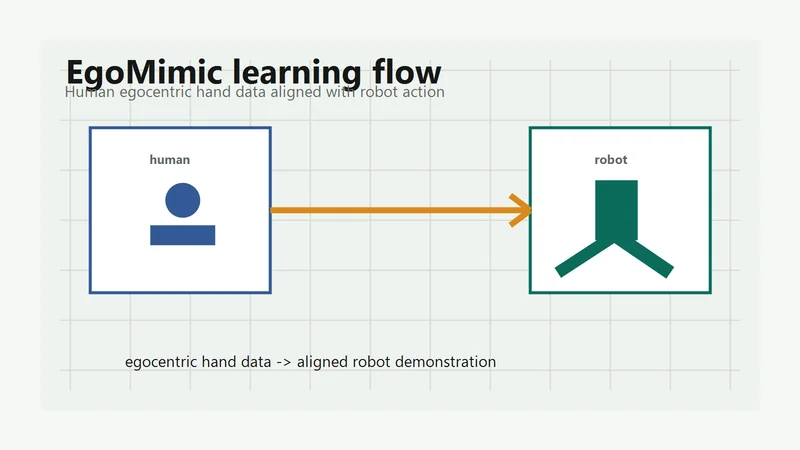
EgoMimic co-trains on human egocentric demonstrations and robot data through 3D hand tracking, cross-domain alignment, and an imitation-learning architecture.