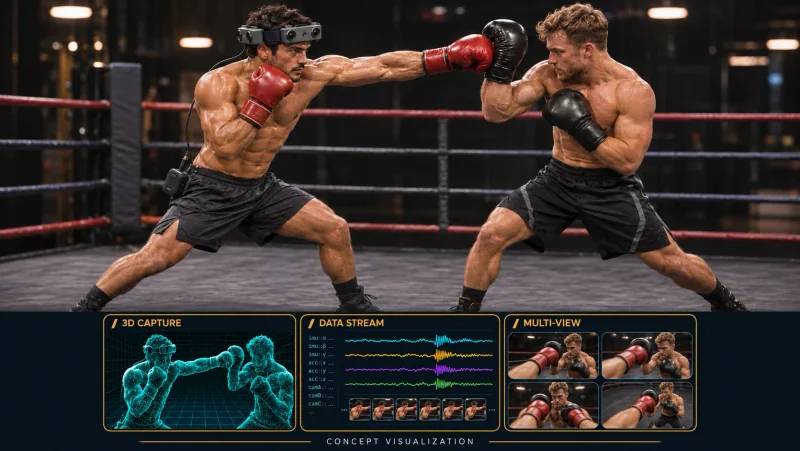
Plan 3D hand object interaction data collection with R10: record a sparring round in synchronized views and manually index glove contact, recovery and guard changes.
Source: BoxingVI: Action Intervals /Author: TINTELE GLOBAL CO., LIMITED Editorial Team
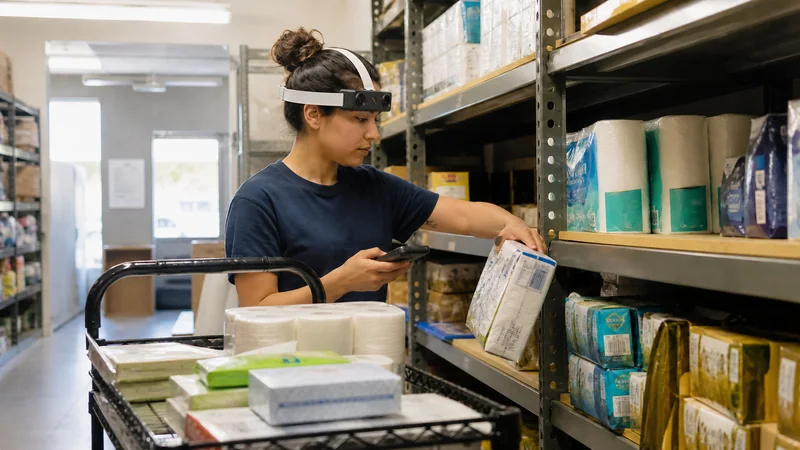
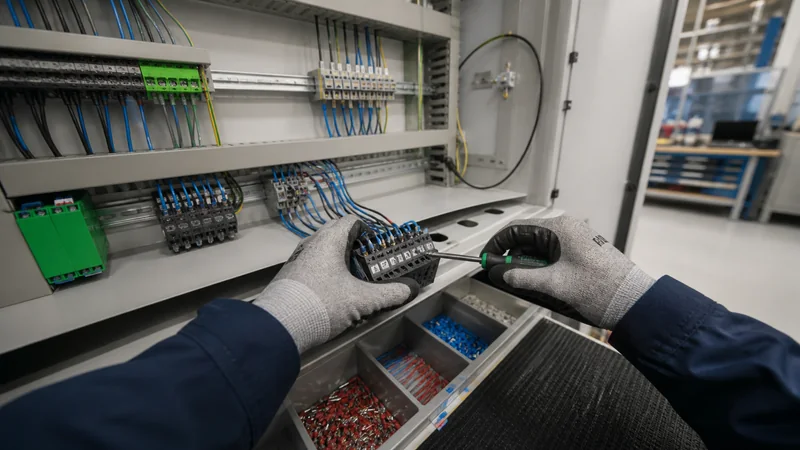
Routine work such as scanning, sorting, restocking, packing, and tidying contains the hand-object sequences robots need to learn. Ego2Robot shows how first-person demonstrations could be transformed at scale.
Author: TINTELE GLOBAL CO., LIMITED Editorial Team Source: Ego2Robot / arXiv
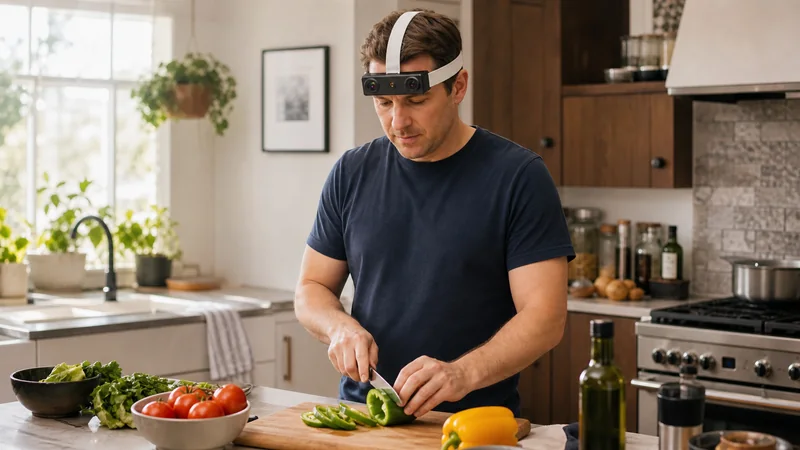
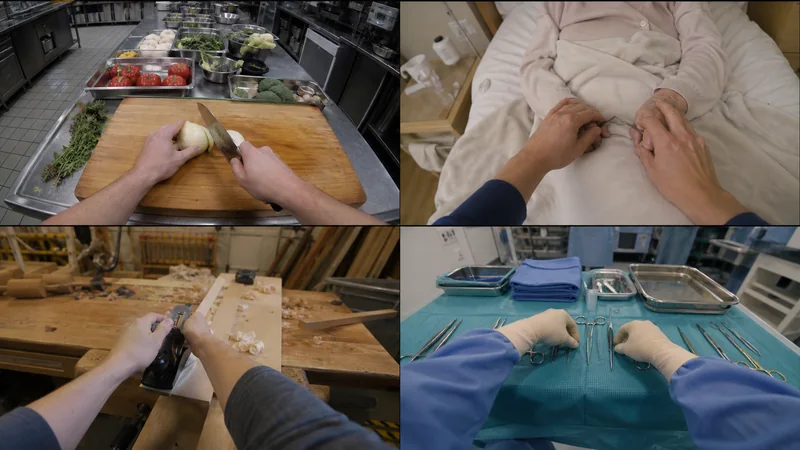
Cooking, cleaning, organizing, and simple repairs contain rich contact and motion patterns. EgoInfinity illustrates how ordinary video can be lifted into structured 4D hand-object interaction data.
Author: TINTELE GLOBAL CO., LIMITED Editorial Team Source: Rice RobotPI Lab / EgoInfinity
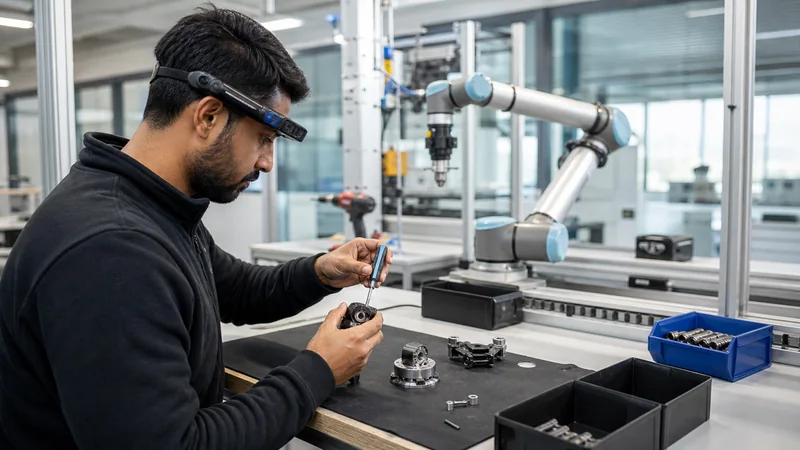
The next leap in robotics depends on more than stronger models. It requires structured, physically realistic data that teaches machines how people perceive, move, manipulate objects, and complete real tasks.
Author: TINTELE GLOBAL CO., LIMITED Editorial Team Source: EGO R9 Field Notes
A practical look at how consistent first-person R9 capture can turn cooking, household care, craft, and training workflows into structured learning material for robots.
Author: TINTELE GLOBAL CO., LIMITED Editorial Team Source: EGO R9 Field Notes
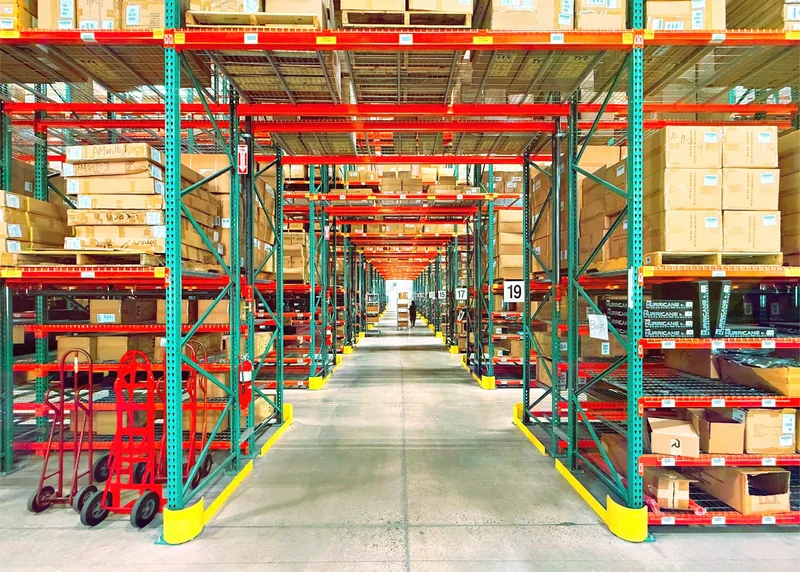
A practical field guide to collecting first-person pick, scan, carry, and exception-handling data with U.S. warehouse associates—while protecting safety, privacy, and worker trust.
Author: TINTELE GLOBAL CO., LIMITED Editorial Team Source: EGO R9 Field Notes, informed by OSHA