
0%
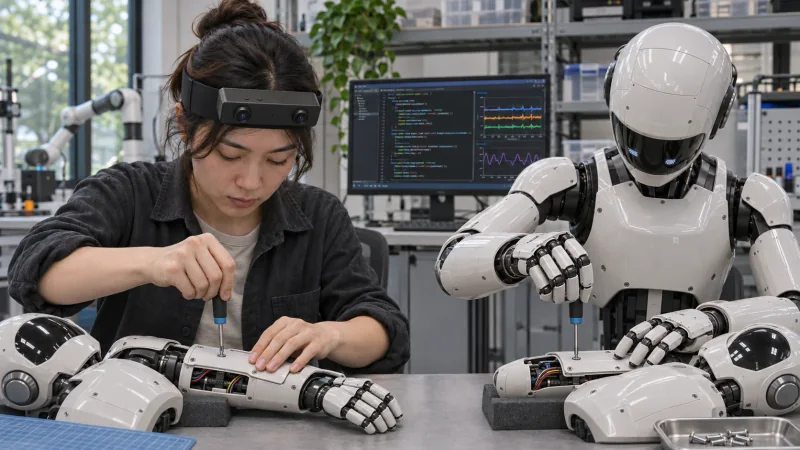
First Person Video Data Collection: Robot Screws with R8
Use EGO R8 first person video data collection to record stereo and IMU data for robot screw assembly and human demonstration research.
Read detailsLatest Blog / Nov 20, 2026
Plan 3D hand object interaction data collection with R10: record a sparring round in synchronized views and manually index glove contact, recovery and guard changes.
Read latest blog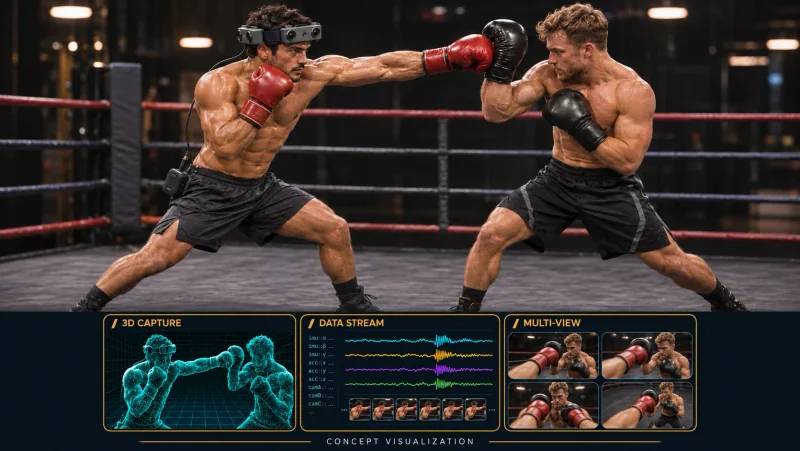
All Blogs / Newest first
Every article keeps its author, source, publication date, image, and local detail page.
Use EGO R8 first person video data collection to record stereo and IMU data for robot screw assembly and human demonstration research.
Read details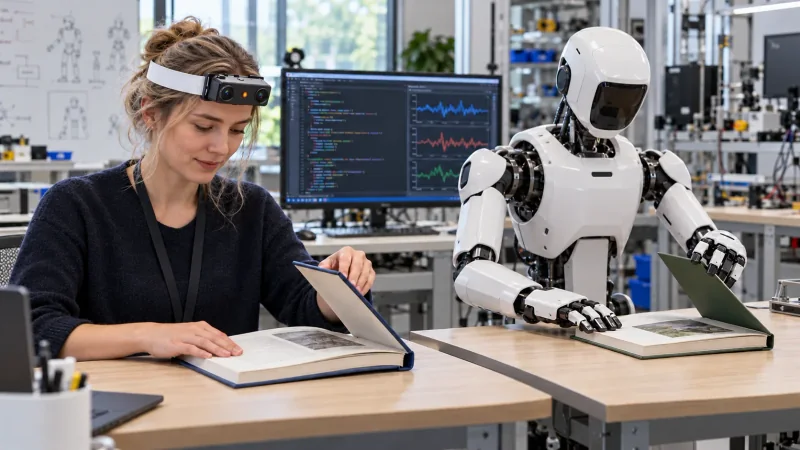
Explore visual inertial data collection with EGO R9 for book-closing demonstrations, combining first-person video and head-unit IMU records.
Read details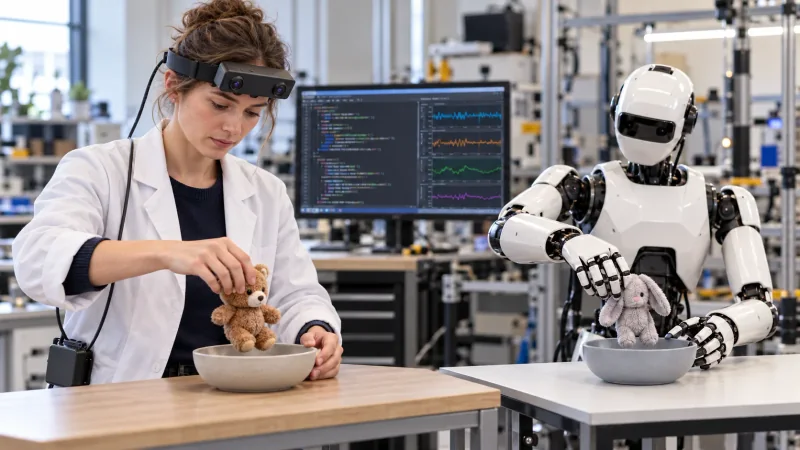
Use EGO R8 egocentric video with IMU to organize repeated object-in-bowl demonstrations for robot-learning research.
Read details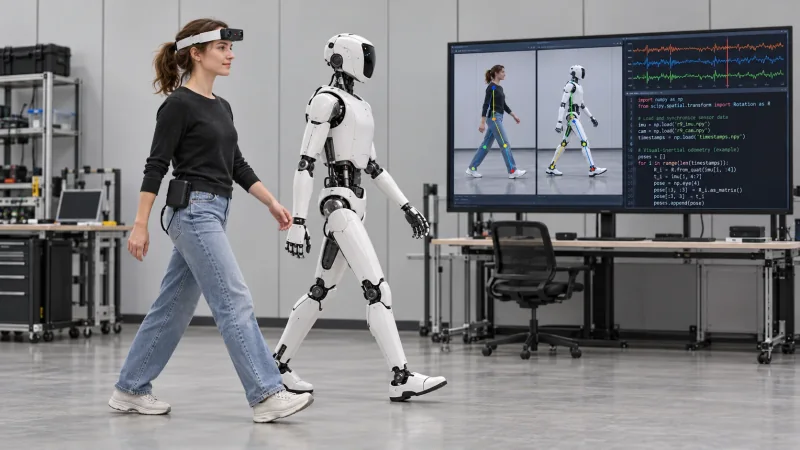
Plan SLAM dataset collection with EGO R9 for low-texture indoor passages using 1080P global-shutter video and timestamped inertial data.
Read details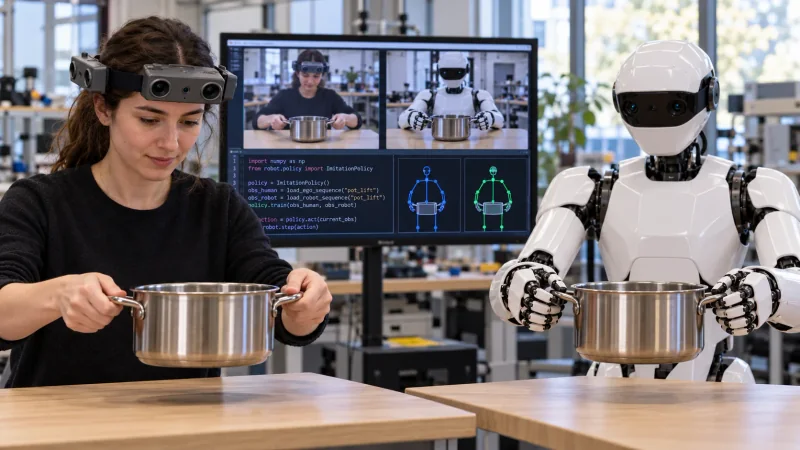
Use EGO R10 synchronized human demonstration data to study two-handed pot lifting, from handle contact to placement, for robot learning.
Read details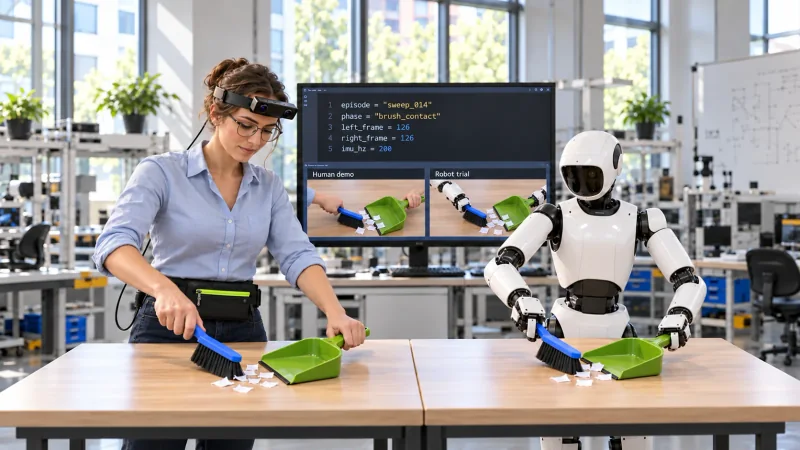
Plan AI training video collection with EGO R8 for tabletop sweeping: global-shutter stereo, hardware synchronization and timestamped visual-inertial records.
Read details


