
0%
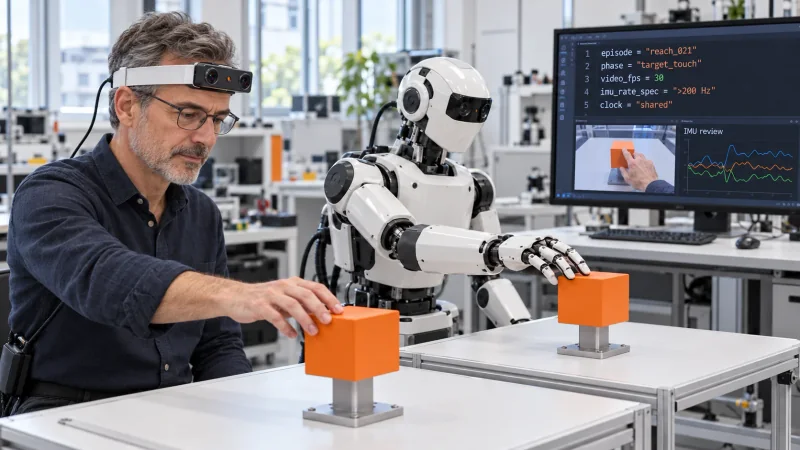
Visual Inertial Data Collection: Target Reaching with R9
Plan visual inertial data collection with EGO R9 for target-reaching research: 1080P global-shutter video, a six-axis IMU above 200 Hz and shared timing.
Read detailsLatest Blog / Nov 20, 2026
Plan 3D hand object interaction data collection with R10: record a sparring round in synchronized views and manually index glove contact, recovery and guard changes.
Read latest blog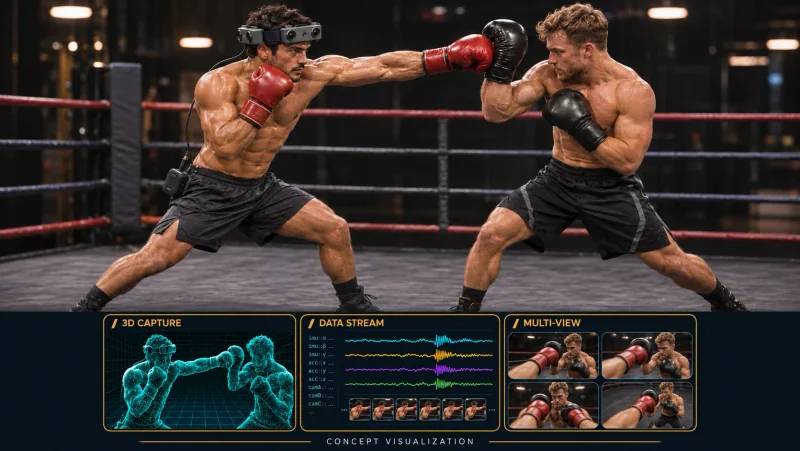
All Blogs / Newest first
Every article keeps its author, source, publication date, image, and local detail page.
Plan visual inertial data collection with EGO R9 for target-reaching research: 1080P global-shutter video, a six-axis IMU above 200 Hz and shared timing.
Read details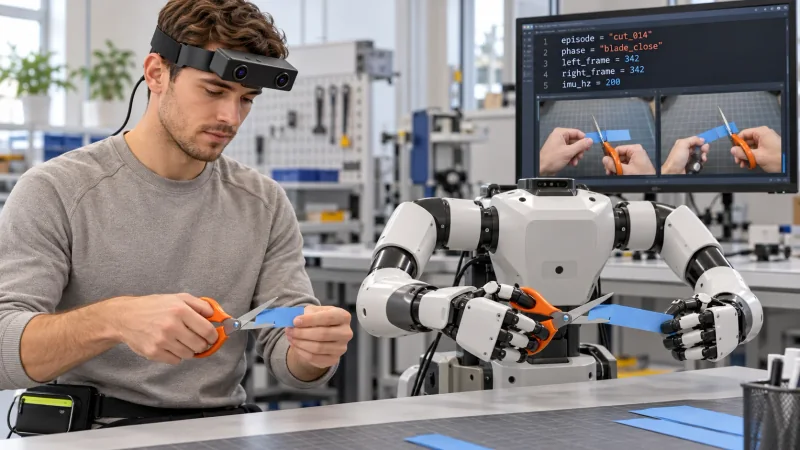
Use EGO R8 as a wearable camera for research on bimanual scissor cutting, with synchronized stereo, shared camera–IMU timing and reviewed task labels.
Read details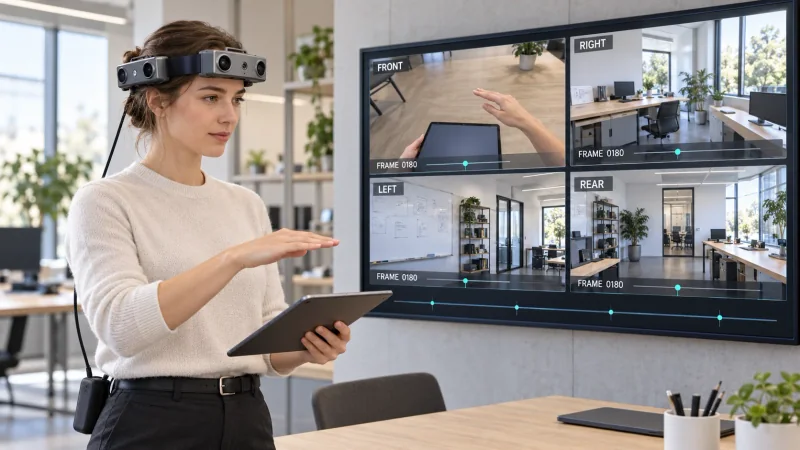
Collect synchronized multi-view spatial data with R10: 1600 × 1200 at 30 fps, shared camera triggering and a focused hand-gesture review workflow.
Read details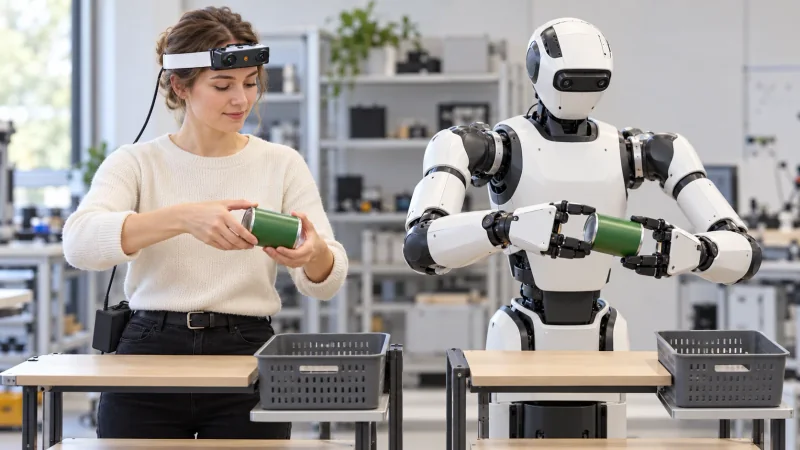
Plan a multi-view egocentric camera study with R9: record shelf-to-hand-to-basket transfers using 1080P global-shutter video and timestamped review.
Read details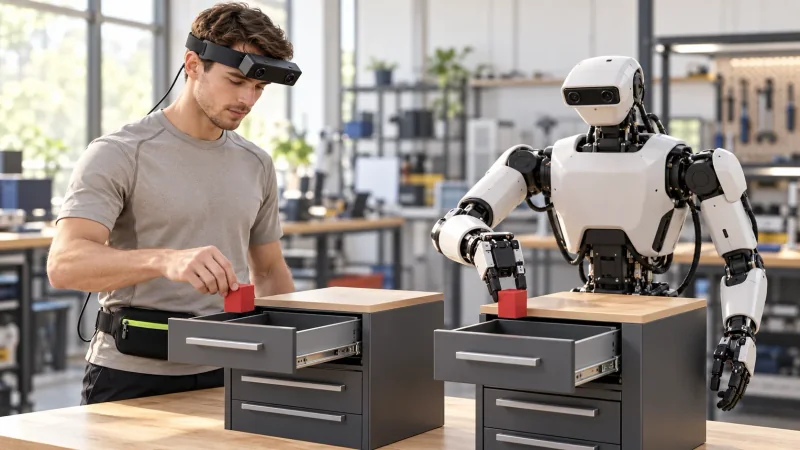
Use R8 as a wearable camera for research into drawer placement: synchronized global-shutter stereo, timestamped review and corresponding human-robot task phases.
Read details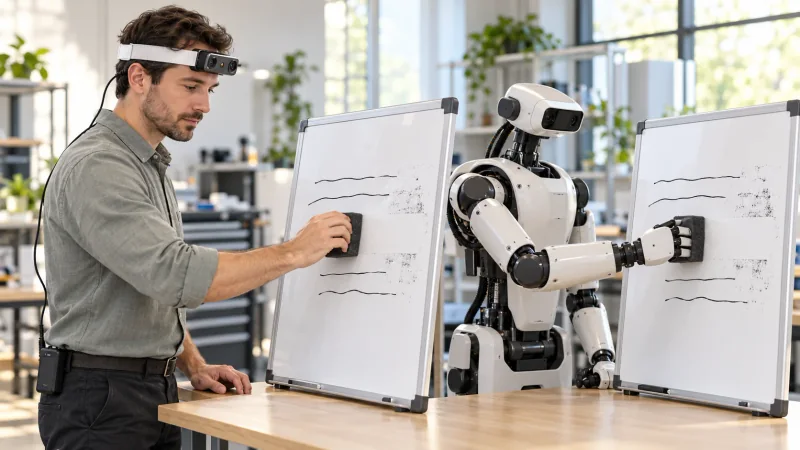
Record egocentric video for robot learning with R9: 1080P, 30 FPS whiteboard-erasing demonstrations, timestamped review and corresponding robot task phases.
Read details


